


ADAS-TO: A Large-Scale Multimodal Naturalistic Dataset and Empirical Characterization of Human Takeovers during ADAS Engagement
Paper • 2603.06986 • Published
1,342 real-world takeover events · 16 vehicle models · 7 manufacturers · 15 files per clip



📢 What this repository is. ADAS-TO-Sample contains every clip of six anonymized drivers from the full ADAS-TO corpus. Paths, file schema and anonymization are identical to the full dataset: any clip here exists at the same path in
HenryYHW/ADAS-TO. For the full dataset (16,446 clips, ~41 GB) request access at HenryYHW/ADAS-TO or contact henryyuhangwang@gmail.com. Paper: arXiv:2603.06986.
Each GIF shows ±3 seconds around the takeover moment — ADAS engaged → driver takes control
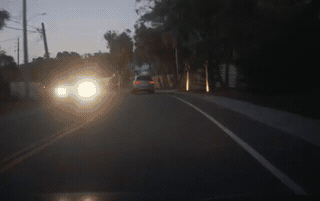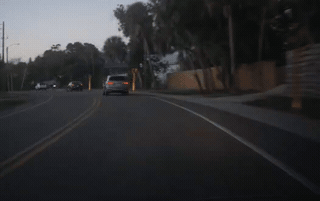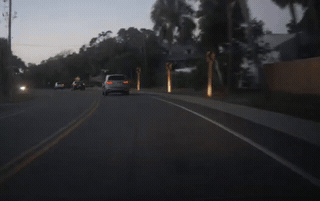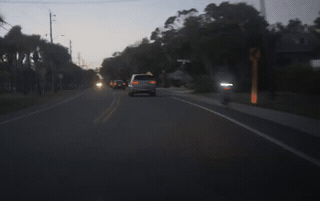 On-coming Traffic |
 Bridge |
 Night Driving |
 Sharp Curve |
 Surrounding Car |
 Traffic Light |
 Lane Change |
 Hard Brake |
| Statistic | Value | |
|---|---|---|
| 🎥 | Takeover clips | 1,342 |
| 🧑✈️ | Drivers | 6 (anonymized driver_124, driver_232, driver_251, driver_277, driver_347, driver_348) |
| 🛣️ | Routes | 311 |
| 🚘 | Vehicle models | 16 |
| 🏭 | Manufacturers | 7 (Ford, Honda, Hyundai, Kia, Tesla, Toyota, Volkswagen) |
| ⏱️ | Clip duration | 20 seconds (±10 s around the takeover) |
| 📹 | Video | Front-facing camera, 20 fps |
| 📡 | CAN / sensor logs | 100 Hz (rlog, 679 clips) or 10 Hz (qlog, 663 clips) |
| 📁 | Files per clip | 15 (1 video + 1 meta + 13 CSV) |
| 💾 | Size | ~3.7 GB (20,130 files) |
| 📦 | Full dataset | 16,446 clips · 364 drivers · 179 vehicle models · ~41 GB (ADAS-TO) |
| Vehicle model | Clips | Vehicle model | Clips |
|---|---|---|---|
| HONDA_CIVIC | 366 | HONDA_ACCORD_HYBRID_2018 | 65 |
| TESLA_MODEL_X | 118 | TOYOTA_CAMRY_TSS2 | 64 |
| TESLA_AP3_MODEL_3 | 117 | VOLKSWAGEN_TIGUAN_MK2 | 53 |
| HYUNDAI_IONIQ_5 | 112 | KIA_EV6 | 42 |
| TOYOTA_RAV4_TSS2_2023 | 108 | KiaNiro2023 | 33 |
| TOYOTA_CAMRY_2021 | 88 | TOYOTA_RAV4_2023 | 23 |
| FORD_MUSTANG_MACH_E_MK1 | 72 | KIA_NIRO_EV_2ND_GEN | 9 |
| HYUNDAI_IONIQ_5_2022 | 71 | FORD_MAVERICK_MK1 | 1 |
driver_NNN / route_MMM to real device or route IDs is not released.ADAS-TO-Sample/
├── <CAR_MODEL>/ # e.g. HONDA_CIVIC, TESLA_AP3_MODEL_3
│ └── <driver_NNN>/ # 🔒 anonymized driver ID
│ └── <route_MMM>/ # 🔒 anonymized route ID
│ └── <clip_id>/ # integer, 0-indexed within the route
│ ├── 🎥 takeover.mp4 20 s front-view video (20 fps)
│ ├── 📋 meta.json clip metadata & timing
│ ├── 🚗 carState.csv speed, accel, steering, pedals, cruise state
│ ├── 🎮 carControl.csv lateral/longitudinal commands
│ ├── ⚙️ carOutput.csv actuator outputs
│ ├── 🤖 controlsState.csv ADAS controller state & alerts
│ ├── 🧠 drivingModelData.csv lane-line estimates, desired curvature
│ ├── 📏 longitudinalPlan.csv planner targets, FCW
│ ├── 📡 radarState.csv lead-vehicle radar tracks
│ ├── 📐 accelerometer.csv IMU acceleration
│ ├── 🧭 VehicleIMU.csv body-frame IMU / yaw rate
│ ├── 🌀 Gyroscope.csv angular rates
│ ├── 📷 CameraOdometry.csv visual odometry
│ ├── 🎯 LiveCalibration.csv device → vehicle frame calibration
│ └── 🔧 LiveParameters.csv online vehicle-parameter estimates
└── annotations/
└── clip_final_labels.csv # scenario label per clip (see below)
15 files per clip (1 video + 1 metadata + 13 CSVs). Vehicle logs are sampled at 100 Hz where an
rlog was available (meta.json: log_kind), otherwise at the 10 Hz qlog rate; video is 20 fps.
annotations/clip_final_labels.csv has one row per clip (1,342 rows) with the anonymized
clip_path, car_model, clip_id, the scenario label final_label, lc_direction (left/right for
lane changes), human_labeled / human_label (manual review status) and realign_status.
final_label |
n | Meaning |
|---|---|---|
cover |
651 | Maneuver-Filtered ADAS — ordinary lane-keeping / car-following, no maneuver confound |
lane_change |
252 | lane transition, merge or fork (lc_direction gives left/right) |
turn |
220 | intersection turn or departure from the through path |
stop |
194 | stopping / decelerating for a traffic control |
Unknown/other |
25 | complex geometry, non-routine scene, or insufficient evidence |
Most analyses should start from cover, which removes disengagements that are explained by a planned
maneuver rather than by the automation reaching its limits.
  ◄──────── 10 seconds ────────►◄──────── 10 seconds ────────►
  ┌──────────────────────────────┬──────────────────────────────┐
  │      🤖 ADAS ENGAGED         │      👤 MANUAL CONTROL        │
  │   (automation driving)       │   (driver takes over)        │
  └──────────────────────────────┴──────────────────────────────┘
                                 ▲
                            TAKEOVER EVENT
                         (ON → OFF transition)
A takeover event is detected as an ADAS ON → OFF transition satisfying:
| Criterion | Value |
|---|---|
| ADAS engaged | controlsState.enabled OR cruiseState.enabled |
| Min ON duration | ≥ 2 seconds before disengagement |
| Min OFF duration | ≥ 2 seconds after disengagement |
| Gap merging | Transient gaps < 0.5 s merged (filters sensor noise) |
| Clip window | ±10 seconds centered on the transition (20 s total) |
| Field | Type | Description |
|---|---|---|
car_model |
string | Vehicle model (e.g., HONDA_CIVIC) |
dongle_id |
string | Anonymized driver ID (driver_NNN) |
route_id |
string | Anonymized route ID (route_MMM) |
log_kind |
string | Log resolution: qlog (10 Hz) or rlog (100 Hz) |
log_hz |
int | CAN signal sampling rate |
vid_kind |
string | Camera source type |
camera_fps |
int | Video frame rate (20 fps) |
clip_id |
int | Clip index within route (0-indexed) |
event_mono |
int | Monotonic timestamp of takeover (ns) |
video_time_s |
float | Takeover time within full route video (s) |
clip_start_s |
float | Clip start time within route (s) |
clip_dur_s |
float | Clip duration (s) |
seg_nums_used |
list | Route segments the clip was cut from |
| Column | Unit | Description |
|---|---|---|
vEgo |
m/s | Ego vehicle speed |
aEgo |
m/s² | Ego vehicle acceleration |
steeringAngleDeg |
deg | Steering wheel angle |
steeringTorque |
N·m | Driver steering torque |
steeringPressed |
bool | Driver actively steering |
gasPressed |
bool | Gas pedal pressed |
brakePressed |
bool | Brake pedal pressed |
cruiseState.enabled |
bool | Cruise / ADAS engaged |
| Column | Unit | Description |
|---|---|---|
enabled |
bool | ADAS system enabled |
active |
bool | ADAS actively controlling vehicle |
curvature |
1/m | Current path curvature |
desiredCurvature |
1/m | Target curvature from planner |
vCruise |
m/s | Set cruise speed |
longControlState |
enum | Longitudinal control state |
alertText1 |
string | Primary driver alert |
alertText2 |
string | Secondary driver alert |
| Column | Unit | Description |
|---|---|---|
latActive |
bool | Lateral control active |
longActive |
bool | Longitudinal control active |
actuators.accel |
m/s² | Commanded acceleration |
actuators.torque |
N·m | Commanded steering torque |
actuators.curvature |
1/m | Commanded path curvature |
| Column | Description |
|---|---|
actuatorsOutput.accel |
Acceleration actuator output |
actuatorsOutput.brake |
Brake actuator output |
actuatorsOutput.gas |
Gas actuator output |
actuatorsOutput.steer |
Steering actuator output |
actuatorsOutput.steerOutputCan |
Raw CAN steering output |
actuatorsOutput.steeringAngleDeg |
Steering angle output (deg) |
| Column | Description |
|---|---|
action.desiredCurvature |
Model-predicted desired curvature |
action.desiredAcceleration |
Model-predicted desired acceleration |
laneLineMeta.leftProb |
Left lane line detection probability |
laneLineMeta.rightProb |
Right lane line detection probability |
| Column | Unit | Description |
|---|---|---|
leadOne.dRel |
m | Distance to primary lead vehicle |
leadOne.vRel |
m/s | Relative velocity of lead |
leadOne.vLead |
m/s | Absolute velocity of lead |
leadOne.aLeadK |
m/s² | Lead vehicle acceleration |
leadTwo.* |
— | Secondary lead vehicle (same fields) |
| Column | Unit | Description |
|---|---|---|
acceleration.v |
m/s² | 3-axis acceleration vector |
timestamp |
— | Sensor timestamp |
| Column | Unit | Description |
|---|---|---|
aTarget |
m/s² | Target acceleration |
hasLead |
bool | Lead vehicle detected |
fcw |
bool | Forward collision warning active |
speeds[] |
m/s | Planned speed profile |
accels[] |
m/s² | Planned acceleration profile |
Body-frame IMU and yaw rate, raw angular rates, visual odometry, the device-to-vehicle calibration,
and the online vehicle-parameter estimates of the openpilot stack, each with the same time base as
the other CSV files. Column names follow the corresponding openpilot cereal message fields.
import json
import pandas as pd
from huggingface_hub import hf_hub_download

repo_id = "HenryYHW/ADAS-TO-Sample"

# pick a clip from the annotation table
labels = pd.read_csv(hf_hub_download(repo_id, "annotations/clip_final_labels.csv", repo_type="dataset"))
clip_path = labels.loc[labels.final_label == "cover", "clip_path"].iloc[0]

# 📋 metadata
with open(hf_hub_download(repo_id, f"{clip_path}/meta.json", repo_type="dataset")) as f:
    meta = json.load(f)

# 🚗 vehicle state signals
car_state = pd.read_csv(hf_hub_download(repo_id, f"{clip_path}/carState.csv", repo_type="dataset"))
print(meta["car_model"], car_state[["vEgo", "aEgo", "steeringAngleDeg", "brakePressed"]].describe())
# Using huggingface-cli (recommended)
huggingface-cli download HenryYHW/ADAS-TO-Sample --repo-type dataset --local-dir ./ADAS-TO-Sample

# Using git-lfs
git lfs install
git clone https://huggingface.co/datasets/HenryYHW/ADAS-TO-Sample
The full ADAS-TO corpus contains 16,446 takeover clips from 364 drivers, 179 vehicle models and 2,585 routes (~41 GB), plus the safety-critical case annotations.
👉 Access the full dataset: HenryYHW/ADAS-TO
For questions or full dataset access, contact: henryyuhangwang@gmail.com
driver_NNN,
route_MMM); the mapping to real device IDs is not released.If you use ADAS-TO in your research, please cite the arXiv paper (arXiv:2603.06986):
@article{wang2026adasto,
  title   = {ADAS-TO: A Large-Scale Multimodal Naturalistic Dataset and
             Empirical Characterization of Human Takeovers during ADAS Engagement},
  author  = {Wang, Yuhang and Xu, Yiyao and Sun, Jingran and Zhou, Hao},
  journal = {arXiv preprint arXiv:2603.06986},
  year    = {2026},
  url     = {https://arxiv.org/abs/2603.06986}
}
This dataset is released under CC BY-NC 4.0.
For academic and non-commercial research purposes.
Built with ❤️ for the autonomous driving research community